The DIY robotics revolution is officially moving at breakneck speed! 🤖🔥 Meet the 3D-Printed Differential Robot Wrist by Source-Robotics—a game-changing open-source mechanism designed to give robot arms precise, multi-axis motion without requiring expensive industrial hardware.
Whether you’re building an AI-powered arm, exploring advanced mechatronics, or upgrading your maker setup, this project provides everything you need to build your own high-performance robot wrist at home.
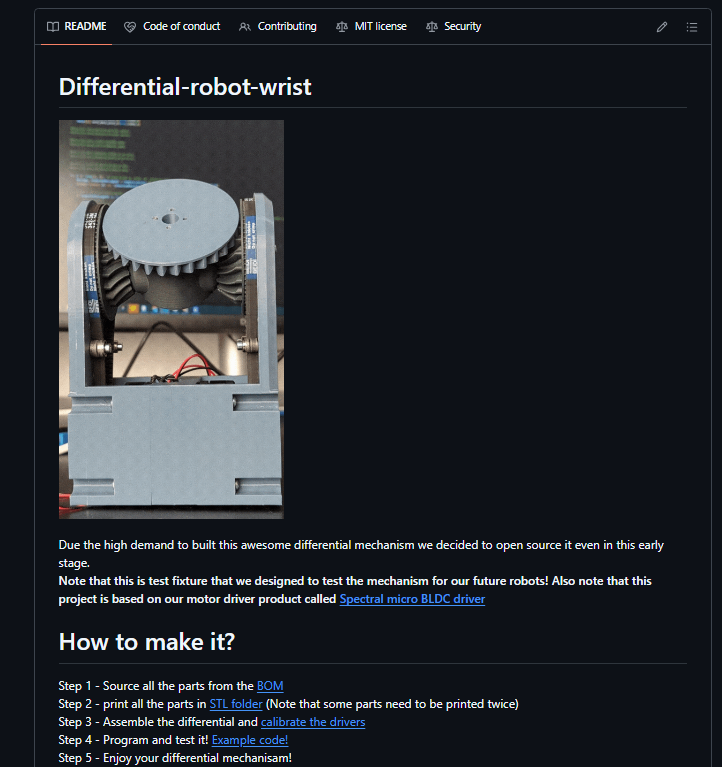
✨ Why This Project Matters
- Full Open-Source Access: CAD models, 3D printable STL files, and tested code are completely free and public.
- Compact Differential Drive: Uses dual BLDC motors operating together to deliver smooth pitch and roll movement in a tight footprint.
- Accessible Hardware: Engineered to be printed on standard desktop 3D printers using readily available components.
🛠️ Quick Build Guide: How to Make It
1.Source Your Components:Check the GitHub repository first.
Grab the full Bill of Materials (BOM) from the project repository to order your bearings, belts, hardware, and BLDC motors.
2.3D Print the Structure:Pay attention to part counts.
Print all STL files. Double-check the printing notes—several structural components require duplicate prints for symmetric assembly.
3.Calibrate the Motor Drivers:Do this BEFORE tensioning belts.
Calibrate your motor drivers following the project’s driver calibration guide prior to attaching the timing belts to avoid binding or damage.
4.Assemble the Mechanism:Use repo reference images.
Follow the step-by-step visual references in the official images folder to align the gears, belt drives, and differential frame.
5.Program & Test:Run example scripts.
Flash the provided example code, run basic movement sequences, and watch your open-source differential wrist come to life!
🔗 Get Started & Contribute
Ready to start printing? Grab the source files, CAD models, and code directly from GitHub:
👉 Source-Robotics/Differential-robot-wrist on GitHub
Project credit: Source-Robotics