Open-Source Adaptive Electric Gripper
Open-source robotics keeps getting better. The SSG-48 Adaptive Electric Gripper is a fully open-source robotic gripper with force control, built by Source Robotics. It works with ROS2 and a Python API, and its parts can be 3D printed. It suits makers, students, researchers and anyone building their own robot.
What Is the SSG-48 Adaptive Electric Gripper?
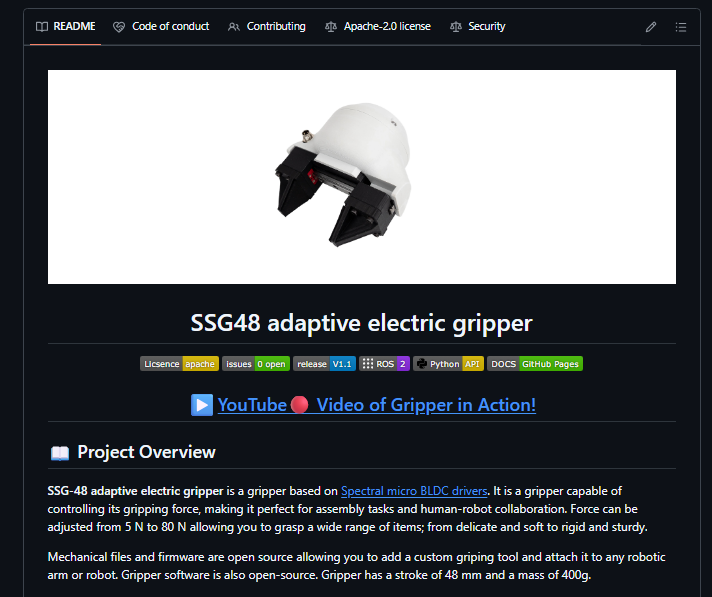
The SSG-48 is an open-source electric robot gripper built on Spectral micro BLDC drivers. It controls its own grip force, so it can handle both delicate and heavy objects. That makes it a good fit for assembly tasks and human-robot collaboration.
The mechanical files, firmware and software are all open source. You can attach custom gripping tools and mount it on almost any robot arm.
Key Specs at a Glance
| Feature | Details |
|---|---|
| Grip force | Adjustable from 5 N to 80 N |
| Stroke | 48 mm |
| Weight | 400 g |
| Driver | Spectral micro BLDC controller |
| Software | Python API, GUI software, ROS2 package |
| Simulation files | URDF and MJCF models |
| License | Apache 2.0 |
Top Features
⚙️ Adaptive force control. Set the grip force from 5 N to 80 N. The gripper can hold a soft object without crushing it, then switch to something rigid and heavy.
🐍 Python API. Control the gripper with a few lines of Python. The repo includes a quick-start example, so you can get it moving fast.
🤖 ROS2 support. A ROS2 package is available, so the gripper fits into modern robotics and AI-robot workflows.
🖨️ 3D-printable parts. The repo includes STL files, STEP files, jaw designs, a full BOM and an assembly manual. Building one at home is realistic.
🧪 Simulation-ready. URDF and MJCF description files let you test your setup in simulation before building.
🔓 Truly open source. Mechanical files, firmware and software are all available under the Apache 2.0 license.
Who Is It For?
- Robotics hobbyists and makers building a DIY robot arm
- Students and researchers working on manipulation and grasping
- AI and robot-learning projects that need a controllable end effector
- Automation and prototyping where you need a compliant gripper
- Open-source hardware fans who want to see inside and modify everything
How to Get Started
- Source the parts from the BOM in the GitHub repo.
- Print the parts using the STL files.
- Follow the assembly manual or the video instructions.
- Set up the software with the Python API, the GUI or the ROS2 package.
- Customize your jaws for your own application.
Prefer not to source everything yourself? A ready-made version is also sold on the Source Robotics website.
⚠️ Safety Note
The project’s own documentation warns that the designs are experimental and involve hazardous voltages. Read the safety and disclaimer document in the repo before building.
Get the Files
👉 GitHub: SSG-48 Adaptive Electric Gripper
Credit: Project by Source Robotics.
FAQ
Is the SSG-48 gripper really open source?
Yes. The mechanical files, firmware and software are open source under the Apache 2.0 license.
Does it support ROS2 and Python?
Yes. There is a Python API and a ROS2 package for the gripper.
What is the gripping force range?
You can adjust it from 5 N to 80 N.
Can I 3D print it?
The repo provides STL files, STEP files, a BOM and assembly instructions for building your own.
Can I use it on any robot arm?
It’s designed so you can attach it to almost any robot arm or robot.