Meet the DevArm by Seeed Studio:
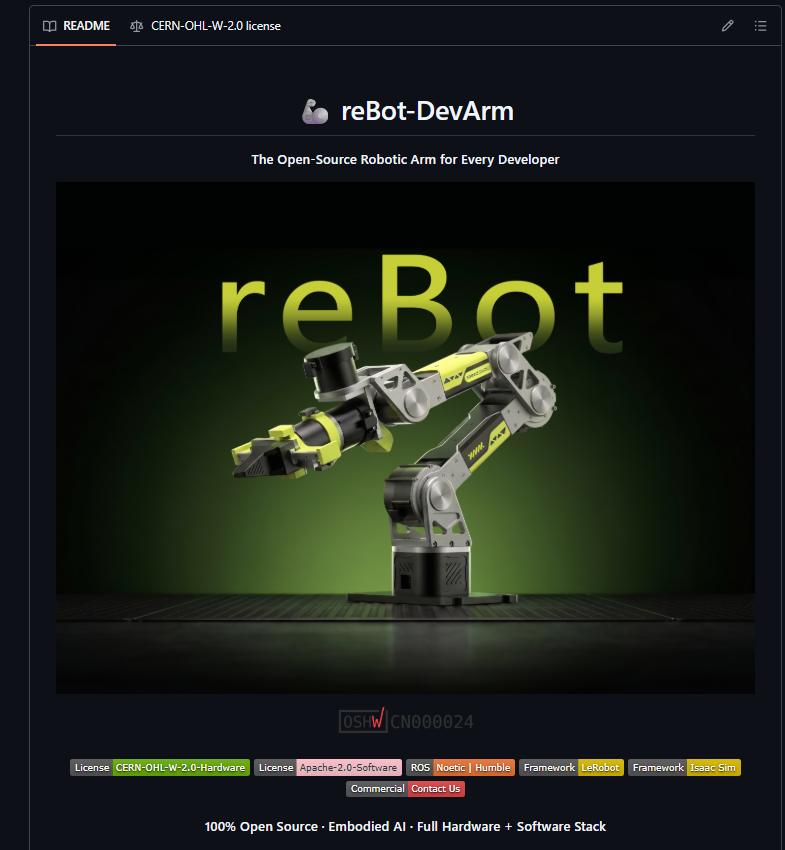
The future of robotics is no longer locked behind proprietary walls or expensive industrial budgets. With the rapid evolution of open-source hardware, makers, students, and developers now have access to enterprise-grade tools right on their desks. Enter the DevArm by Seeed Studio (reBot-DevArm)—a fully open-source, 3D-printable, 6-DOF (Degrees of Freedom) robotic arm built to bridge the gap between hobbyist projects and advanced Embodied AI research.
Whether you are looking to automate repetitive desktop workflows, experiment with computer vision, or train machine learning models using physical AI frameworks, the DevArm offers an accessible, high-performance platform.
What is the DevArm?
Developed by Seeed Studio, the reBot-DevArm (featuring variants like the B601-DM and B601-RS) is a project dedicated to true open-source freedom. Unlike many commercial robotic arms that restrict users to closed ecosystems, everything—from the hardware blueprints and CAD files to the firmware and software stack—is released without reservation.
Key Highlights:
- 100% Open-Source Hardware & Software: Complete access to CAD models, electrical schematics, a detailed Bill of Materials (BOM), and Python/ROS software stacks.
- Industrial-Grade Specs on a Maker Budget: Delivers precise 6-axis articulation with impressive reach and payload capabilities at a fraction of the cost of commercial lab alternatives.
- Embodied AI & Computer Vision Ready: Designed from the ground up to integrate seamlessly with modern AI frameworks like Hugging Face LeRobot, NVIDIA Isaac Sim, and ROS 2.
Core Specifications & Variants
The DevArm line is built to balance physical flexibility with robust payload capacity, making it ideal for desktop AI experimentation:
- Degrees of Freedom: 6-DOF + Gripper
- Build Flexibility: Features 3D-printable structural elements combined with robust metal/motor options (such as the B601-DM and B601-RS configurations).
- Ecosystem Options: Seeed Studio offers multiple kit options ranging from standalone structural/motor kits to fully pre-assembled units, depending on whether you want the satisfaction of a DIY build or immediate out-of-the-box deployment.
What Can You Do With the DevArm?
Because it combines an open hardware blueprint with deep software compatibility, the use cases stretch far beyond basic pick-and-place routines:
- Grab & Sort Objects: Utilize computer vision pipelines (such as depth cameras like the Intel RealSense D405 mounted eye-in-hand) to detect, track, and sort objects by color, shape, or tags.
- Embodied AI & Machine Learning: Train your robotic arm using imitation learning and end-to-end robot learning frameworks like Hugging Face LeRobot. Feed natural language commands (e.g., “pick up the red block”) and watch the arm auto-plan and execute.
- Simulation & Digital Twins: Test your control algorithms safely in NVIDIA Isaac Sim before deploying them to the physical hardware. You can even check out Seeed’s online web simulations to test kinematics and automation loops in-browser.
- Customization & Upgrades: Want a custom gripper? Need an extended base or custom sensor mounting? Because the design files are entirely open, you can easily tweak the CAD files and 3D print your own custom modifications.
The Open-Source Stack: Hardware + Software
Seeed Studio has ensured that builders aren’t left stranded after assembling the mechanical components. The project repository features:
- Hardware Blueprints: STEP and STL files for 3D-printed and sheet-metal components.
- Detailed BOM: Complete parts lists down to the exact specifications and sourcing links for screws, wiring harnesses, and motors.
- Software Support: Comprehensive Python SDKs, ROS 1 / ROS 2 packages, kinematics solvers (like Pinocchio), and community-driven teleoperation tools.
The Future is Printable
Open-source robotics is accelerating at a staggering pace. Projects like the DevArm lower the financial and technical barriers that used to keep advanced robotics confined to industrial floors and university research labs.
Whether you’re a student looking to break into robotics engineering, a developer exploring spatial AI, or a maker wanting a heavy-duty desktop arm for your workshop, the DevArm provides an incredible canvas.
Ready to Build Your Own?
Explore the documentation, check out the BOM, and view the online simulations directly via the official repository: